From NeRFs to Nimble Robots: LERF TOGO's Leap in Zero-Shot Grasping and Semantic Understanding

It's no secret there are a large amount of use cases for NeRFs. Recently, I took a look at Infinite Realities and examined some of human based ones.

It's no secret there are a large amount of use cases for NeRFs. Recently, I took a look at Infinite Realities and examined some of human based ones.

Michael Rubloff

Michael Rubloff

Michael is the Founder and Managing Editor of Radiancefields.com

LERF TOGO

It’s no secret there are a large amount of use cases for NeRFs. Recently, I took a look at Infinite Realities and examined some of human based ones.

However, today we’re going to look at a new paper that builds on top of one of my favorite papers of this year, Language Embedded Radiance Fields (LERF). As a quick reminder, LERF allows you query a part of the NeRF through text. So, for instance, if you had a NeRF of a kitchen and wanted to know everything in it that could clean up a spill, it would point out paper towels, or a mop, or suggest to be less clusmy. Just kidding about that last one, but you get the sense about how it can be utilized.

Where it gets extraordinarily interesting to me are the larger applications of LERF and there are no shortage of them. So I was thrilled when I saw the title of this paper: Language Embedded Radiance Fields for Zero-Shot Task-Oriented Grasping.

As it name implies, this takes LERF a step forward with more granularity. For instance, while the computer may be able to correctly identify a mop to help clean a spill, if it isn’t able to tell you where to grasp it, you might end up with wet hands and a scratched up, still wet floor.

Obviously for a human, we would know not to grab a mop by the head, but for all the use cases where we might not interact often— say robotics, it becomes critical. The method behind this is called task-oriented grasping and can be defined by correctly grasping an object based upon the intention and requested outcome of an action.

LERF TOGO outputs a ranking of viable grasps for the requested object and task. From LERF’s standard 3D relevancy map, LERF TOGO then generates a 3D Object Mask. It does this by rendering a top-down view of the scene and queries the object using LERF to obtain a coarse object localization. It then creates a foreground mask by thresholding the first principal component of the rendered DINO embeddings. The relevancy query is constrained to this mask to pinpoint the most relevant 3D point, which is refined to create a complete object mask.
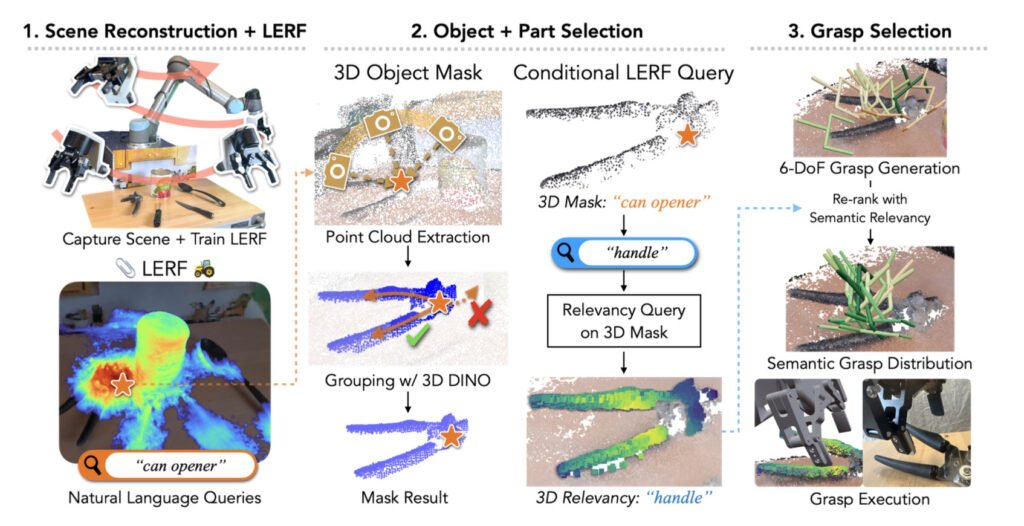
A 3D part relevancy map is then generated with a conditional LERF query over the object part query and the 3D object mask The part relevancy map is used to produce a semantic grasp distribution.

Instead of making a single direct query, LERF-TOGO uses two related queries. Similar to generative modeling where using composed prompts or queries can guide the model towards specific properties or outputs. By combining related queries, it can specify the exact part or attribute of an object that it’s interested in. LERF, by design, is “scale-conditioned.” This means when you give it a query, it doesn’t just look for that object or feature at one fixed size. It searches over multiple scales (or sizes) to find the best representation of that object or feature in the image. In the normal process, LERF would return the relevancy (or match) at the scale where the object or feature has the highest activation or recognition.

With LERF-TOGO, instead of searching everywhere, the search is restricted or “conditioned” to only the points that are within the previously identified 3D object mask. This conditioned search is like telling LERF, “Only look for the handle within the regions we’ve identified”. By doing this, the model will generate a distribution over the object’s 3D structure, indicating the likelihood of each point being the specific desired object part.

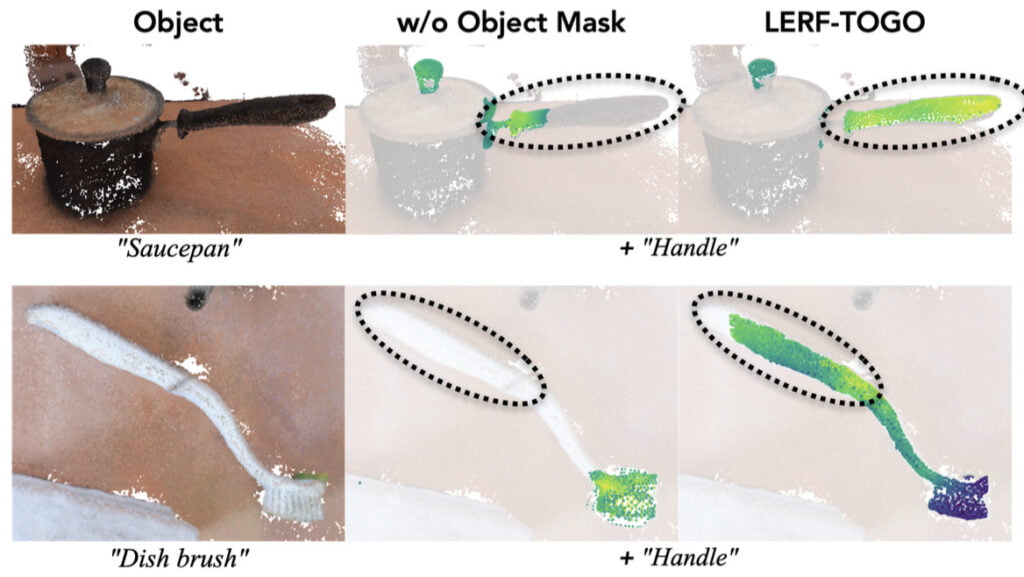
We can see how having the 3D Object Mask dramatically helps the system understand where it should be focusing.
The experiments perform admirably in the first step. It’s able to achieve a 96% on first locating the requested item. However, that’s not necessarily new as that’s what OG LERF does. What really matters is how successful is it in locating the correct place to grab an object? A resounding 82%! But that’s still not the final answer we’re looking for. Now that we know both the object and the location, can a robot actually grab it with the information it has? Yes, it can 69% of the time. Nice. Separately, they ran it through a purely LLM generated prompt and it was successful 96% and 71% of the time identifying and then grasping the correct part.

In order to actually qualify as a successful grasp, the team considers it a success”if it lifts the correct object using the appropriate subpart at least 10cm vertically, and the object remains securely within the gripper jaws throughout.” They found that LERF TOGO is also able to understand more minute details, such as if something is described as “matte” or “shiny”.
Ideally we’re looking for a smaller drop off from the original 96%, as we move through the phases, but this represents tremendous applications for robotics, automation, and maintenance.

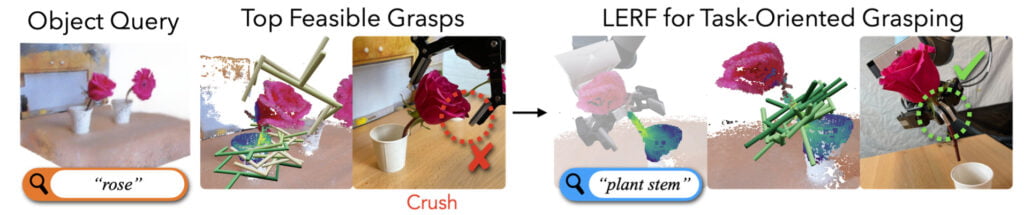
Where LERF TOGO comes up short is differentiating similar looking items on the same object, such as a teapots handle or spout. Clearly, the LLM has never heard the song, I’m a Little Teapot. LERF TOGO also takes a couple of minutes to run in its current form, training to roughly 2K steps. While that may seem fast, it does invalidate high pressure use cases for now, such as the room is on fire, help me put it out. Interestingly, once the NeRF is trained, it only takes LERF TOGO 10 seconds to run. Another place it struggles is where there are several objects overlapping in the foreground, such as flowers in a vase.

The code has not been released yet, but when it is, I think we will see LERF TOGO on nerfstudio.

I strongly believe that LERF will continue to have downstream effects for NeRFs and various industries that begin to grasp (pun intended) what can be done. I’m looking forward to seeing more innovation in semantic processing of NeRFs and will be following this closely.

Thumbnail for Gaussian Splatting News episode 12

11:38

Watch · New every Monday

Splats Come to Fortnite, Nike Shoots in 4D, Splats on a Nintendo 3DS

Episode 12 · Nov 9, 2026

Epic’s UEFN 43.00 brings Gaussian splats into the Unreal Editor for Fortnite, importing PLY and SPZ files that render on every platform UEFN supports, mobile included.

Featured

Recents

Platforms

World Labs Opens Atlas World Model to Everyone

World Labs has opened Atlas to everyone, launching Viewfinder, Chisel, Splats to Mesh and Relight alongside a developer API that outputs SPZ Gaussian splats.

Michael Rubloff

Nov 13, 2026

Platforms

World Labs Opens Atlas World Model to Everyone

World Labs has opened Atlas to everyone, launching Viewfinder, Chisel, Splats to Mesh and Relight alongside a developer API that outputs SPZ Gaussian splats.

Michael Rubloff

Platforms

OfflineTools' Frankensplat Trains Splats in the Browser

Frankensplat from OfflineTools trains Gaussian splats locally in the browser on WebGPU from images and a COLMAP reconstruction, with live PSNR and PLY export.

Michael Rubloff

Nov 13, 2026

Platforms

OfflineTools' Frankensplat Trains Splats in the Browser

Frankensplat from OfflineTools trains Gaussian splats locally in the browser on WebGPU from images and a COLMAP reconstruction, with live PSNR and PLY export.

Michael Rubloff

Platforms

Evergine Moves Gaussian Splat Processing to the GPU

Evergine's November 2026 release moves its Gaussian Splatting add-on to GPU compute shaders and adds PLY, SPZ, KSplat, LCC and LCC2 loading with auto-detection.

Michael Rubloff

Nov 12, 2026

Platforms

Evergine Moves Gaussian Splat Processing to the GPU

Evergine's November 2026 release moves its Gaussian Splatting add-on to GPU compute shaders and adds PLY, SPZ, KSplat, LCC and LCC2 loading with auto-detection.

Michael Rubloff

Platforms

Spirula Studio v2026.11.12 Adds Calibration Correction

Spirula Studio v2026.11.12 corrects rolling shutter and other camera calibration residuals during training and adds an experimental GLOMAP-style SfM mapper.

Michael Rubloff

Nov 12, 2026

Platforms

Spirula Studio v2026.11.12 Adds Calibration Correction

Spirula Studio v2026.11.12 corrects rolling shutter and other camera calibration residuals during training and adds an experimental GLOMAP-style SfM mapper.

Michael Rubloff

Trending Articles
  1. TRENDING
    Loading...
  2. TRENDING
    Loading...
  3. TRENDING
    Loading...
Michael Rubloff

Written by Michael Rubloff

Michael is the Founder and Managing Editor of Radiancefields.com

More from Michael Rubloff

More from Michael Rubloff

Platforms

World Labs Opens Atlas World Model to Everyone

World Labs has opened Atlas to everyone, launching Viewfinder, Chisel, Splats to Mesh and Relight alongside a developer API that outputs SPZ Gaussian splats.

Michael Rubloff

Nov 13, 2026

Atlas World Labs

Platforms

World Labs Opens Atlas World Model to Everyone

Michael Rubloff

Nov 13, 2026

Atlas World Labs

Platforms

World Labs Opens Atlas World Model to Everyone

World Labs has opened Atlas to everyone, launching Viewfinder, Chisel, Splats to Mesh and Relight alongside a developer API that outputs SPZ Gaussian splats.

Michael Rubloff

Nov 13, 2026

Atlas World Labs

Platforms

OfflineTools' Frankensplat Trains Splats in the Browser

Frankensplat from OfflineTools trains Gaussian splats locally in the browser on WebGPU from images and a COLMAP reconstruction, with live PSNR and PLY export.

Michael Rubloff

Nov 13, 2026

Frankensplat

Platforms

OfflineTools' Frankensplat Trains Splats in the Browser

Michael Rubloff

Nov 13, 2026

Frankensplat

Platforms

OfflineTools' Frankensplat Trains Splats in the Browser

Frankensplat from OfflineTools trains Gaussian splats locally in the browser on WebGPU from images and a COLMAP reconstruction, with live PSNR and PLY export.

Michael Rubloff

Nov 13, 2026

Frankensplat

Platforms

Evergine Moves Gaussian Splat Processing to the GPU

Evergine's November 2026 release moves its Gaussian Splatting add-on to GPU compute shaders and adds PLY, SPZ, KSplat, LCC and LCC2 loading with auto-detection.

Michael Rubloff

Nov 12, 2026

Evergine Gaussian Splatting

Platforms

Evergine Moves Gaussian Splat Processing to the GPU

Michael Rubloff

Nov 12, 2026

Evergine Gaussian Splatting

Platforms

Evergine Moves Gaussian Splat Processing to the GPU

Evergine's November 2026 release moves its Gaussian Splatting add-on to GPU compute shaders and adds PLY, SPZ, KSplat, LCC and LCC2 loading with auto-detection.

Michael Rubloff

Nov 12, 2026

Evergine Gaussian Splatting

New to Gaussian Splatting? Start here

Radiance fields, explained from the ground up: what a Gaussian splat is, how to capture one, and which tools and gear to start with.

Newsletter

Keep up with the field.

New research, tools and captures from the Radiance Fields newsroom, in your inbox. Free, no spam.

Gaussian Splatting News on YouTube

The week in radiance fields, every Monday.

Gaussian Splatting News on YouTube

The week in radiance fields, every Monday.

Gaussian Splatting News on YouTube

The week in radiance fields, every Monday.

Gaussian Splatting News on YouTube

The week in radiance fields, every Monday.