N-Dimensional Gaussians for Fitting of High Dimensional Functions

It significantly improves the fidelity of reflections and other view-dependent effects, making scenes look more realistic.

It significantly improves the fidelity of reflections and other view-dependent effects, making scenes look more realistic.

Michael Rubloff

Michael Rubloff

Michael is the Founder and Managing Editor of Radiancefields.com

Tags

N-Dimensional Gaussians for Fitting of High Dimensional Functions

In an exciting development, researchers from Intel Labs and Inria have introduced a novel method for fitting high-dimensional functions using N-Dimensional Gaussian (NDG) mixture models. This technique, which will be presented at the SIGGRAPH next week, promises to enhance the efficiency and quality of high-dimensional data representation, making strides in both synthetic scene shading and real-world Radiance Fields.
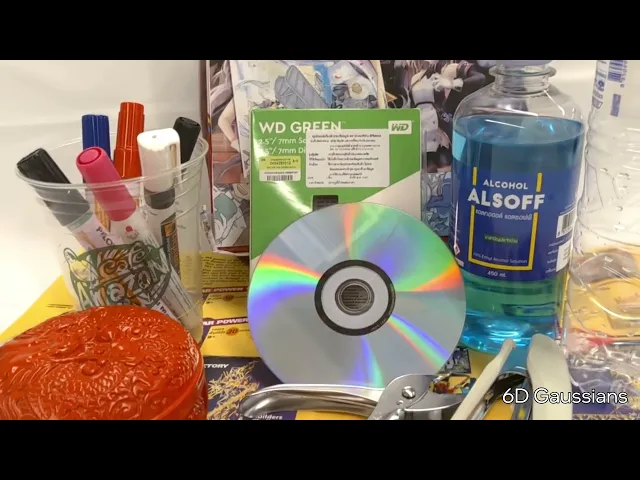
As the complexity of computer graphics increases, so does the dimensionality of the data involved. Traditional methods often struggle to manage dynamic content that varies with numerous parameters, such as material properties, illumination, and temporal changes. The paper "N-Dimensional Gaussians for Fitting of High Dimensional Functions" addresses these challenges by leveraging Gaussian mixture models (GMMs) to create a compact and efficient representation of high-dimensional data.

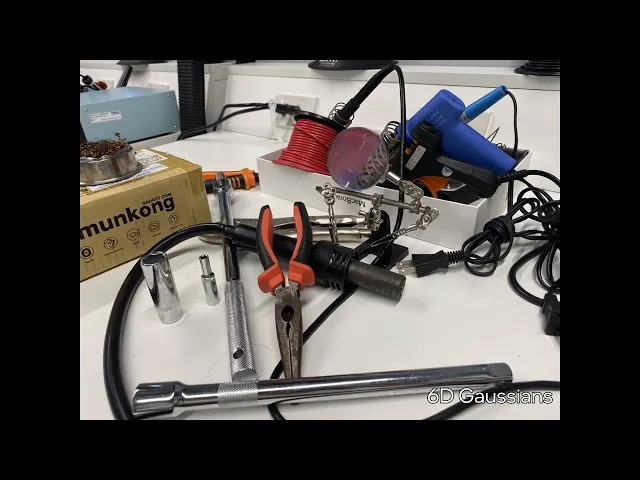
This new method offers several key benefits. It significantly improves the fidelity of reflections and other view-dependent effects, making scenes look more realistic. Additionally, it allows for faster and more accurate rendering of complex scenes, including those with dynamic lighting and material changes. By efficiently managing high-dimensional data, this technique enables the creation of more detailed and lifelike graphics in less time, pushing the boundaries of what is possible in computer graphics.
Inspired by Locality Sensitive Hashing (LSH), this scheme bounds N-dimensional Gaussians, enabling efficient evaluation by discarding irrelevant data early in the process. This reduces computational load and accelerates rendering times.

They also use a Density Control Scheme to adaptively refine, ensuring that additional Gaussian components are introduced only where necessary, optimizing the representation for both compactness and quality. It incrementally guides the inclusion of new details based on the loss function, ensuring a high-quality fit without unnecessary complexity.

A critical aspect of this is the parent-child Gaussian relationship, which plays a significant role in the optimization stage. This relationship involves pairing each Gaussian component (parent) with a nested Gaussian (child), which starts with negligible influence but can become more significant during optimization.

Each parent Gaussian begins with a corresponding child Gaussian that spans the same space. Initially, the child Gaussian has minimal contribution to the overall representation. The child Gaussian is parameterized relative to its parent, meaning any changes to the parent Gaussian automatically influence the child Gaussian's initial position and shape. This ensures smooth transitions and avoids abrupt changes.

During optimization, if the parent Gaussian alone is insufficient to represent the data accurately, the child Gaussian increases its influence. The optimizer controls this process, allowing the child Gaussian to contribute more detail where necessary. The dependency between parent and child prevents redundant or unnecessary Gaussians from being added. The child Gaussian only becomes independent when its contribution reaches a significant threshold.
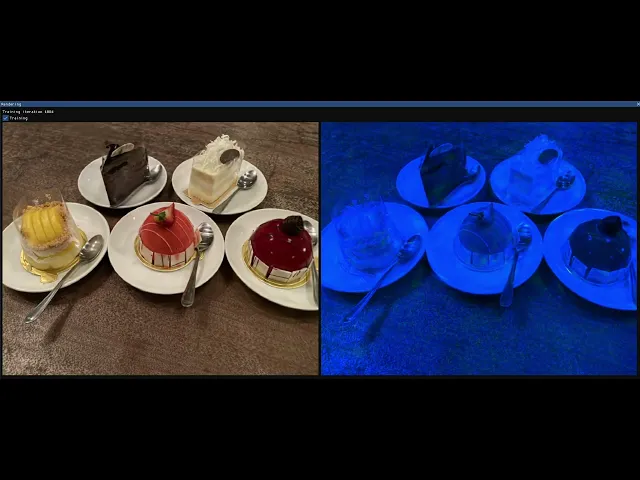
The optimization is conducted in phases, with each phase allowing the Gaussians to stabilize before introducing new child Gaussians every 300 iterations. This phased approach helps manage complexity and ensure incremental improvement.

For novel view synthesis, particularly in scenes with complex view-dependent effects, NDG provides an adaptive and accurate representation. One challenge is the potential for overfitting in high-dimensional data, which requires careful management of training samples and regularization techniques. Additionally, extending the method to handle coherent motion in dynamic scenes presents an interesting avenue for future work.

For more detailed information and access to the code implementation, visit the project page or their GitHub page. Their code is now available with an MIT License and the team will be on site next week at SIGGRAPH in Denver! The code was developed on Windows, but they hope to expand the platforms offered in the future.
Featured

Recents

Platforms

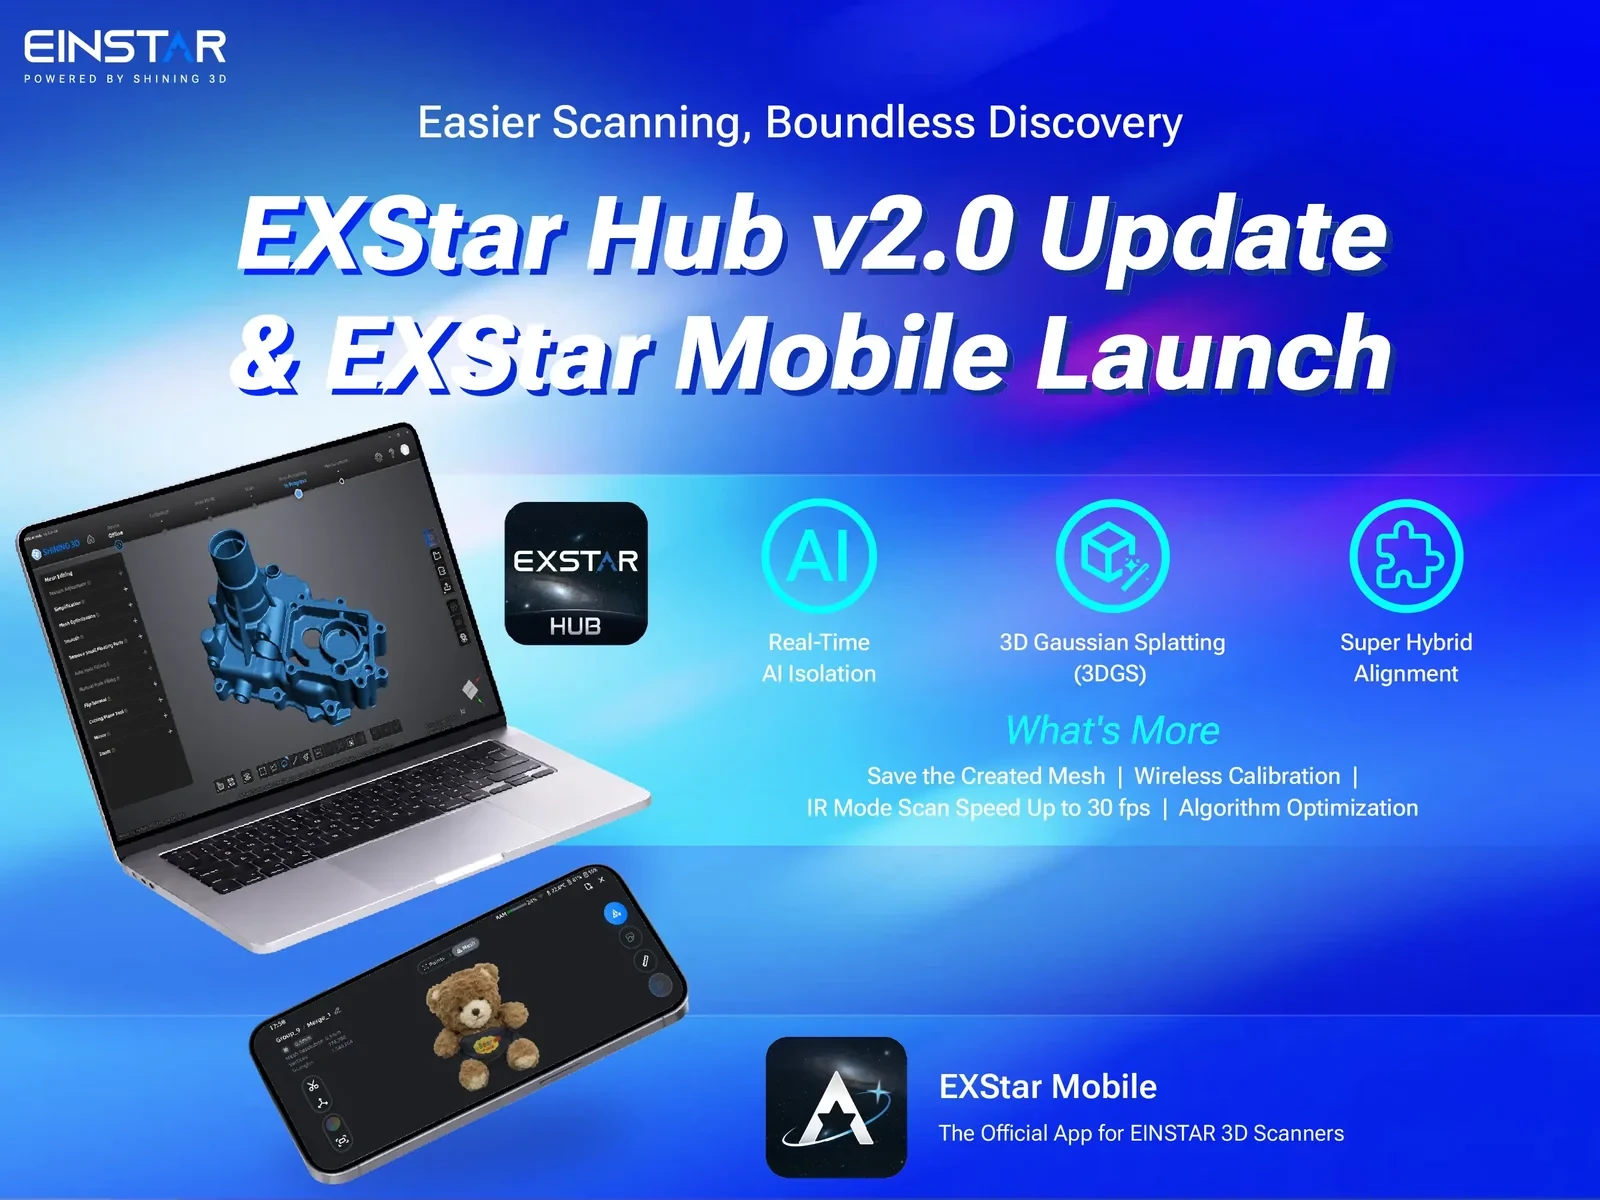
SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

EXStar Hub 2.0 adds cloud-computed 3D Gaussian splatting for the Einstar 2 and Einstar Rockit scanners, alongside a new EXStar Mobile companion app for Android.

Michael Rubloff

Oct 31, 2026

Platforms

SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

EXStar Hub 2.0 adds cloud-computed 3D Gaussian splatting for the Einstar 2 and Einstar Rockit scanners, alongside a new EXStar Mobile companion app for Android.

Michael Rubloff

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Octave Alto 2026.1 adds Gaussian splat support, read as OGC 3D Tiles with glTF payloads, plus live drone video integration and NATO military mapping standards.

Michael Rubloff

Oct 31, 2026

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Octave Alto 2026.1 adds Gaussian splat support, read as OGC 3D Tiles with glTF payloads, plus live drone video integration and NATO military mapping standards.

Michael Rubloff

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

ColmapView Spatial Hub catalogs 4,559 COLMAP-compatible scene entries that open in the browser viewer, and viewer v0.20.1 adds public Share on Hub submissions.

Michael Rubloff

Oct 31, 2026

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

ColmapView Spatial Hub catalogs 4,559 COLMAP-compatible scene entries that open in the browser viewer, and viewer v0.20.1 adds public Share on Hub submissions.

Michael Rubloff

Platforms

Florian Hahlbohm Rebuilds Zip-NeRF in Fused CUDA

Fused Zip-NeRF reimplements Zip-NeRF in hand-written fused CUDA for NeRFICG, which its author says trains 6-7x faster and renders 10x faster at equal quality.

Michael Rubloff

Oct 31, 2026

Platforms

Florian Hahlbohm Rebuilds Zip-NeRF in Fused CUDA

Fused Zip-NeRF reimplements Zip-NeRF in hand-written fused CUDA for NeRFICG, which its author says trains 6-7x faster and renders 10x faster at equal quality.

Michael Rubloff

Trending Articles
  1. TRENDING
    Loading...
  2. TRENDING
    Loading...
  3. TRENDING
    Loading...
Michael Rubloff

Written by Michael Rubloff

Michael is the Founder and Managing Editor of Radiancefields.com

More from Michael Rubloff

More from Michael Rubloff

Platforms

SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

EXStar Hub 2.0 adds cloud-computed 3D Gaussian splatting for the Einstar 2 and Einstar Rockit scanners, alongside a new EXStar Mobile companion app for Android.

Michael Rubloff

Oct 31, 2026

EXStar Hub

Platforms

SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

Michael Rubloff

Oct 31, 2026

EXStar Hub

Platforms

SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

EXStar Hub 2.0 adds cloud-computed 3D Gaussian splatting for the Einstar 2 and Einstar Rockit scanners, alongside a new EXStar Mobile companion app for Android.

Michael Rubloff

Oct 31, 2026

EXStar Hub

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Octave Alto 2026.1 adds Gaussian splat support, read as OGC 3D Tiles with glTF payloads, plus live drone video integration and NATO military mapping standards.

Michael Rubloff

Oct 31, 2026

Octave

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Michael Rubloff

Oct 31, 2026

Octave

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Octave Alto 2026.1 adds Gaussian splat support, read as OGC 3D Tiles with glTF payloads, plus live drone video integration and NATO military mapping standards.

Michael Rubloff

Oct 31, 2026

Octave

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

ColmapView Spatial Hub catalogs 4,559 COLMAP-compatible scene entries that open in the browser viewer, and viewer v0.20.1 adds public Share on Hub submissions.

Michael Rubloff

Oct 31, 2026

Spatial Hub

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

Michael Rubloff

Oct 31, 2026

Spatial Hub

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

ColmapView Spatial Hub catalogs 4,559 COLMAP-compatible scene entries that open in the browser viewer, and viewer v0.20.1 adds public Share on Hub submissions.

Michael Rubloff

Oct 31, 2026

Spatial Hub

New to Gaussian Splatting? Start here

Radiance fields, explained from the ground up: what a Gaussian splat is, how to capture one, and which tools and gear to start with.

Newsletter

Keep up with the field.

New research, tools and captures from the Radiance Fields newsroom, in your inbox. Free, no spam.