
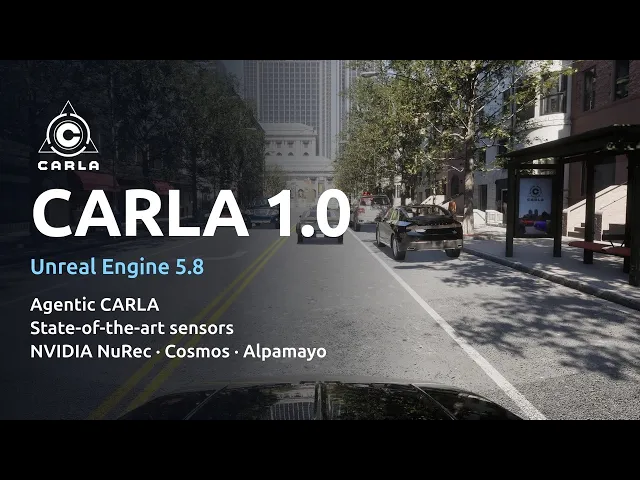
CARLA has released version 1.0 of its open source driving simulator, which turns a recorded real world drive into a simulated scene through NVIDIA NuRec 26.04.
CARLA first added NuRec support in 0.9.16, part of the Unreal Engine 4.26 line that the project now calls obsolete and due for deprecation. NuRec, NVIDIA's neural reconstruction stack, reached general availability on NGC in March as a set of gaussian splatting reconstruction and rendering libraries.
In CARLA 1.0, a NuRec scenario is a .usdz file holding the trained neural scene, the recorded actor tracks and the OpenDRIVE road network. CARLA builds a world from that road network, spawns the recorded actors and owns the physics and the clock. The Neural Reconstruction Engine runs in a container and serves photoreal camera frames and lidar sweeps over gRPC at the poses CARLA reports, with every camera due in a tick rendered in one batched round trip.
The renderer defaults to the backend the artifact was trained for, and nrend or gsplat can be forced in the demo configuration file. The neural lidar models a PANDAR128 or an AT128. After a configurable handoff, the ego can follow the recorded track, re-drive the recorded trajectory with CARLA vehicle physics, or drive freely under the Traffic Manager, and other vehicles can be handed to the Traffic Manager too. Asset editing swaps the rendered asset of one vehicle for another or inserts a clone on a shifted trajectory.
A hybrid example composites CARLA vehicles and pedestrians into the neural scene. CARLA's new ray traced lens cameras render the added actors through the recorded camera's lens, occlusion against the reconstruction is resolved with a distance AOV, and World.set_sky_light_map lights them from the scene's recorded environment. Five Scenic scenarios ship with it, including a highway cut-in and an urban pull-out, so a scripted vehicle can cut in front of the ego inside a real logged drive.
Sample scenes come from NVIDIA's gated PhysicalAI-Autonomous-Vehicles-NuRec dataset on Hugging Face, which runs to about 1.5 terabytes in full.
CARLA 1.0 also moves from Unreal Engine 5.5 to 5.8 on CARLA's own engine fork, adds NVIDIA Cosmos and DLSS 4.5 support, and ships packages for Ubuntu 22.04, Ubuntu 24.04 and Windows 11 alongside a Docker image. CARLA 1.0 is available now on GitHub.


