Scaniverse #SplatYourWorld Challenge Winners Announced

Niantic Spatial names the first Scaniverse #SplatYourWorld Challenge winners, with Hiroto Otsubo's Insta360 X5 capture of Salar de Uyuni taking the Grand Prize.

Niantic Spatial names the first Scaniverse #SplatYourWorld Challenge winners, with Hiroto Otsubo's Insta360 X5 capture of Salar de Uyuni taking the Grand Prize.

Michael Rubloff

Michael Rubloff

Michael is the Founder and Managing Editor of Radiancefields.com

Niantic Spatial

Niantic Spatial has named the winners of the first Scaniverse #SplatYourWorld Challenge, with the Grand Prize going to Hiroto Otsubo for a capture of Salar de Uyuni.

Niantic Spatial opened the challenge in late June, asking entrants to capture real world locations as gaussian splats with Scaniverse and submit an exported .SPZ file alongside a public video walkthrough. Submissions ran from July 1 through July 31, with judging in the first week of August across a Grand Prize and three category prizes for Industrial Environments, Natural Landscapes, and Urban Infrastructure.

Otsubo captured Salar de Uyuni, the salt flat in southwest Bolivia, with an Insta360 X5 at a site more than 3,500 meters above sea level with almost no buildings, trees, or distinct visual landmarks. Judges scored entries on reconstruction quality, scale and coverage, and real world impact. Mohamed Sayed, Senior Research Scientist at Niantic Spatial, called the scene "an open expanse of almost nothing," and said it succeeds through gentle textures in a field where entrants aim to cram the most detail per pixel.
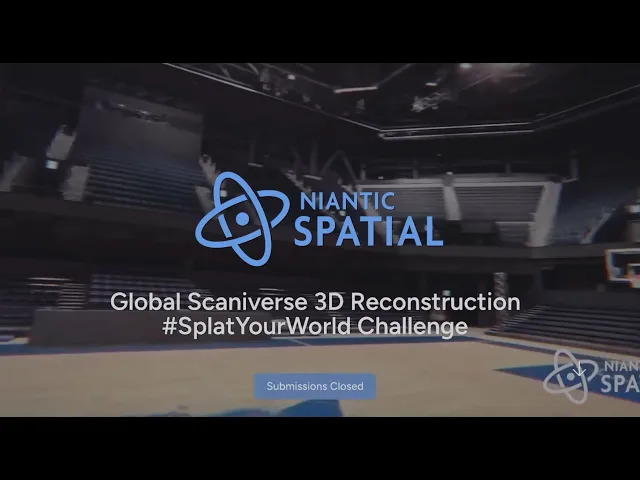
Otsubo said he wanted to see whether Scaniverse could reconstruct "the vastness, reflections, and sense of isolation" that make Uyuni distinct.

Gabriele Romagnoli of XR AI Spotlight took Best Industrial Environment Reconstruction for an aerial capture of the Sleutel Heat Centre Leiden, an industrial waste heating facility, flown with an Antigravity A1 drone. Oliver Johnston, an AI Operations Specialist at Niantic Spatial, pointed to the top dome structures and scaffolding and to the building reflections in the canal.

Razvan Onisca of Archaic Knowledge took Best Natural Landscape Reconstruction for Detunata Goala, a geological site and nature reserve in Transylvania, Romania, captured with a DJI Avata 360 drone.

Romagnoli took the Urban Infrastructure category as well, for the CORPUS Museum in South Holland and its 35 meter tall seated human figure. Romagnoli flew 4 minutes and 25 seconds of 360 degree footage on the Antigravity A1, processed in the cloud with Scaniverse. Jonathan Stephens, Founder of Pixel Reconstruct, said of the reconstruction, "I could see this used for a base of a 3D map."

Honorable mentions went to Beatriz Junquera for the Bates-Scofield Homestead in Darien, Connecticut, and to Justin Ryan for a large scale aerial capture of downtown Chattanooga. Niantic Spatial describes its reconstruction technology as using AI priors to help infer geometry and structure from visual data.

Niantic Spatial is offering new users 105,000 free Scaniverse Top-Up Credits with the code FLEXYOURSCAN through August 31, 2026. Existing users must request a promo code.
Featured

Recents

Platforms

SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

EXStar Hub 2.0 adds cloud-computed 3D Gaussian splatting for the Einstar 2 and Einstar Rockit scanners, alongside a new EXStar Mobile companion app for Android.

Michael Rubloff

Oct 31, 2026

Platforms

SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

EXStar Hub 2.0 adds cloud-computed 3D Gaussian splatting for the Einstar 2 and Einstar Rockit scanners, alongside a new EXStar Mobile companion app for Android.

Michael Rubloff

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Octave Alto 2026.1 adds Gaussian splat support, read as OGC 3D Tiles with glTF payloads, plus live drone video integration and NATO military mapping standards.

Michael Rubloff

Oct 31, 2026

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Octave Alto 2026.1 adds Gaussian splat support, read as OGC 3D Tiles with glTF payloads, plus live drone video integration and NATO military mapping standards.

Michael Rubloff

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

ColmapView Spatial Hub catalogs 4,559 COLMAP-compatible scene entries that open in the browser viewer, and viewer v0.20.1 adds public Share on Hub submissions.

Michael Rubloff

Oct 31, 2026

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

ColmapView Spatial Hub catalogs 4,559 COLMAP-compatible scene entries that open in the browser viewer, and viewer v0.20.1 adds public Share on Hub submissions.

Michael Rubloff

Platforms

Florian Hahlbohm Rebuilds Zip-NeRF in Fused CUDA

Fused Zip-NeRF reimplements Zip-NeRF in hand-written fused CUDA for NeRFICG, which its author says trains 6-7x faster and renders 10x faster at equal quality.

Michael Rubloff

Oct 31, 2026

Platforms

Florian Hahlbohm Rebuilds Zip-NeRF in Fused CUDA

Fused Zip-NeRF reimplements Zip-NeRF in hand-written fused CUDA for NeRFICG, which its author says trains 6-7x faster and renders 10x faster at equal quality.

Michael Rubloff

Trending Articles
  1. TRENDING
    Loading...
  2. TRENDING
    Loading...
  3. TRENDING
    Loading...
Michael Rubloff

Written by Michael Rubloff

Michael is the Founder and Managing Editor of Radiancefields.com

More from Michael Rubloff

More from Michael Rubloff

Platforms

SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

EXStar Hub 2.0 adds cloud-computed 3D Gaussian splatting for the Einstar 2 and Einstar Rockit scanners, alongside a new EXStar Mobile companion app for Android.

Michael Rubloff

Oct 31, 2026

EXStar Hub

Platforms

SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

Michael Rubloff

Oct 31, 2026

EXStar Hub

Platforms

SHINING 3D Adds Gaussian Splatting to EXStar Hub 2.0

EXStar Hub 2.0 adds cloud-computed 3D Gaussian splatting for the Einstar 2 and Einstar Rockit scanners, alongside a new EXStar Mobile companion app for Android.

Michael Rubloff

Oct 31, 2026

EXStar Hub

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Octave Alto 2026.1 adds Gaussian splat support, read as OGC 3D Tiles with glTF payloads, plus live drone video integration and NATO military mapping standards.

Michael Rubloff

Oct 31, 2026

Octave

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Michael Rubloff

Oct 31, 2026

Octave

Platforms

Octave Adds Gaussian Splat Support to Alto 2026.1

Octave Alto 2026.1 adds Gaussian splat support, read as OGC 3D Tiles with glTF payloads, plus live drone video integration and NATO military mapping standards.

Michael Rubloff

Oct 31, 2026

Octave

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

ColmapView Spatial Hub catalogs 4,559 COLMAP-compatible scene entries that open in the browser viewer, and viewer v0.20.1 adds public Share on Hub submissions.

Michael Rubloff

Oct 31, 2026

Spatial Hub

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

Michael Rubloff

Oct 31, 2026

Spatial Hub

Platforms

Yehe Liu Adds a Public Dataset Catalog to ColmapView

ColmapView Spatial Hub catalogs 4,559 COLMAP-compatible scene entries that open in the browser viewer, and viewer v0.20.1 adds public Share on Hub submissions.

Michael Rubloff

Oct 31, 2026

Spatial Hub

New to Gaussian Splatting? Start here

Radiance fields, explained from the ground up: what a Gaussian splat is, how to capture one, and which tools and gear to start with.

Newsletter

Keep up with the field.

New research, tools and captures from the Radiance Fields newsroom, in your inbox. Free, no spam.